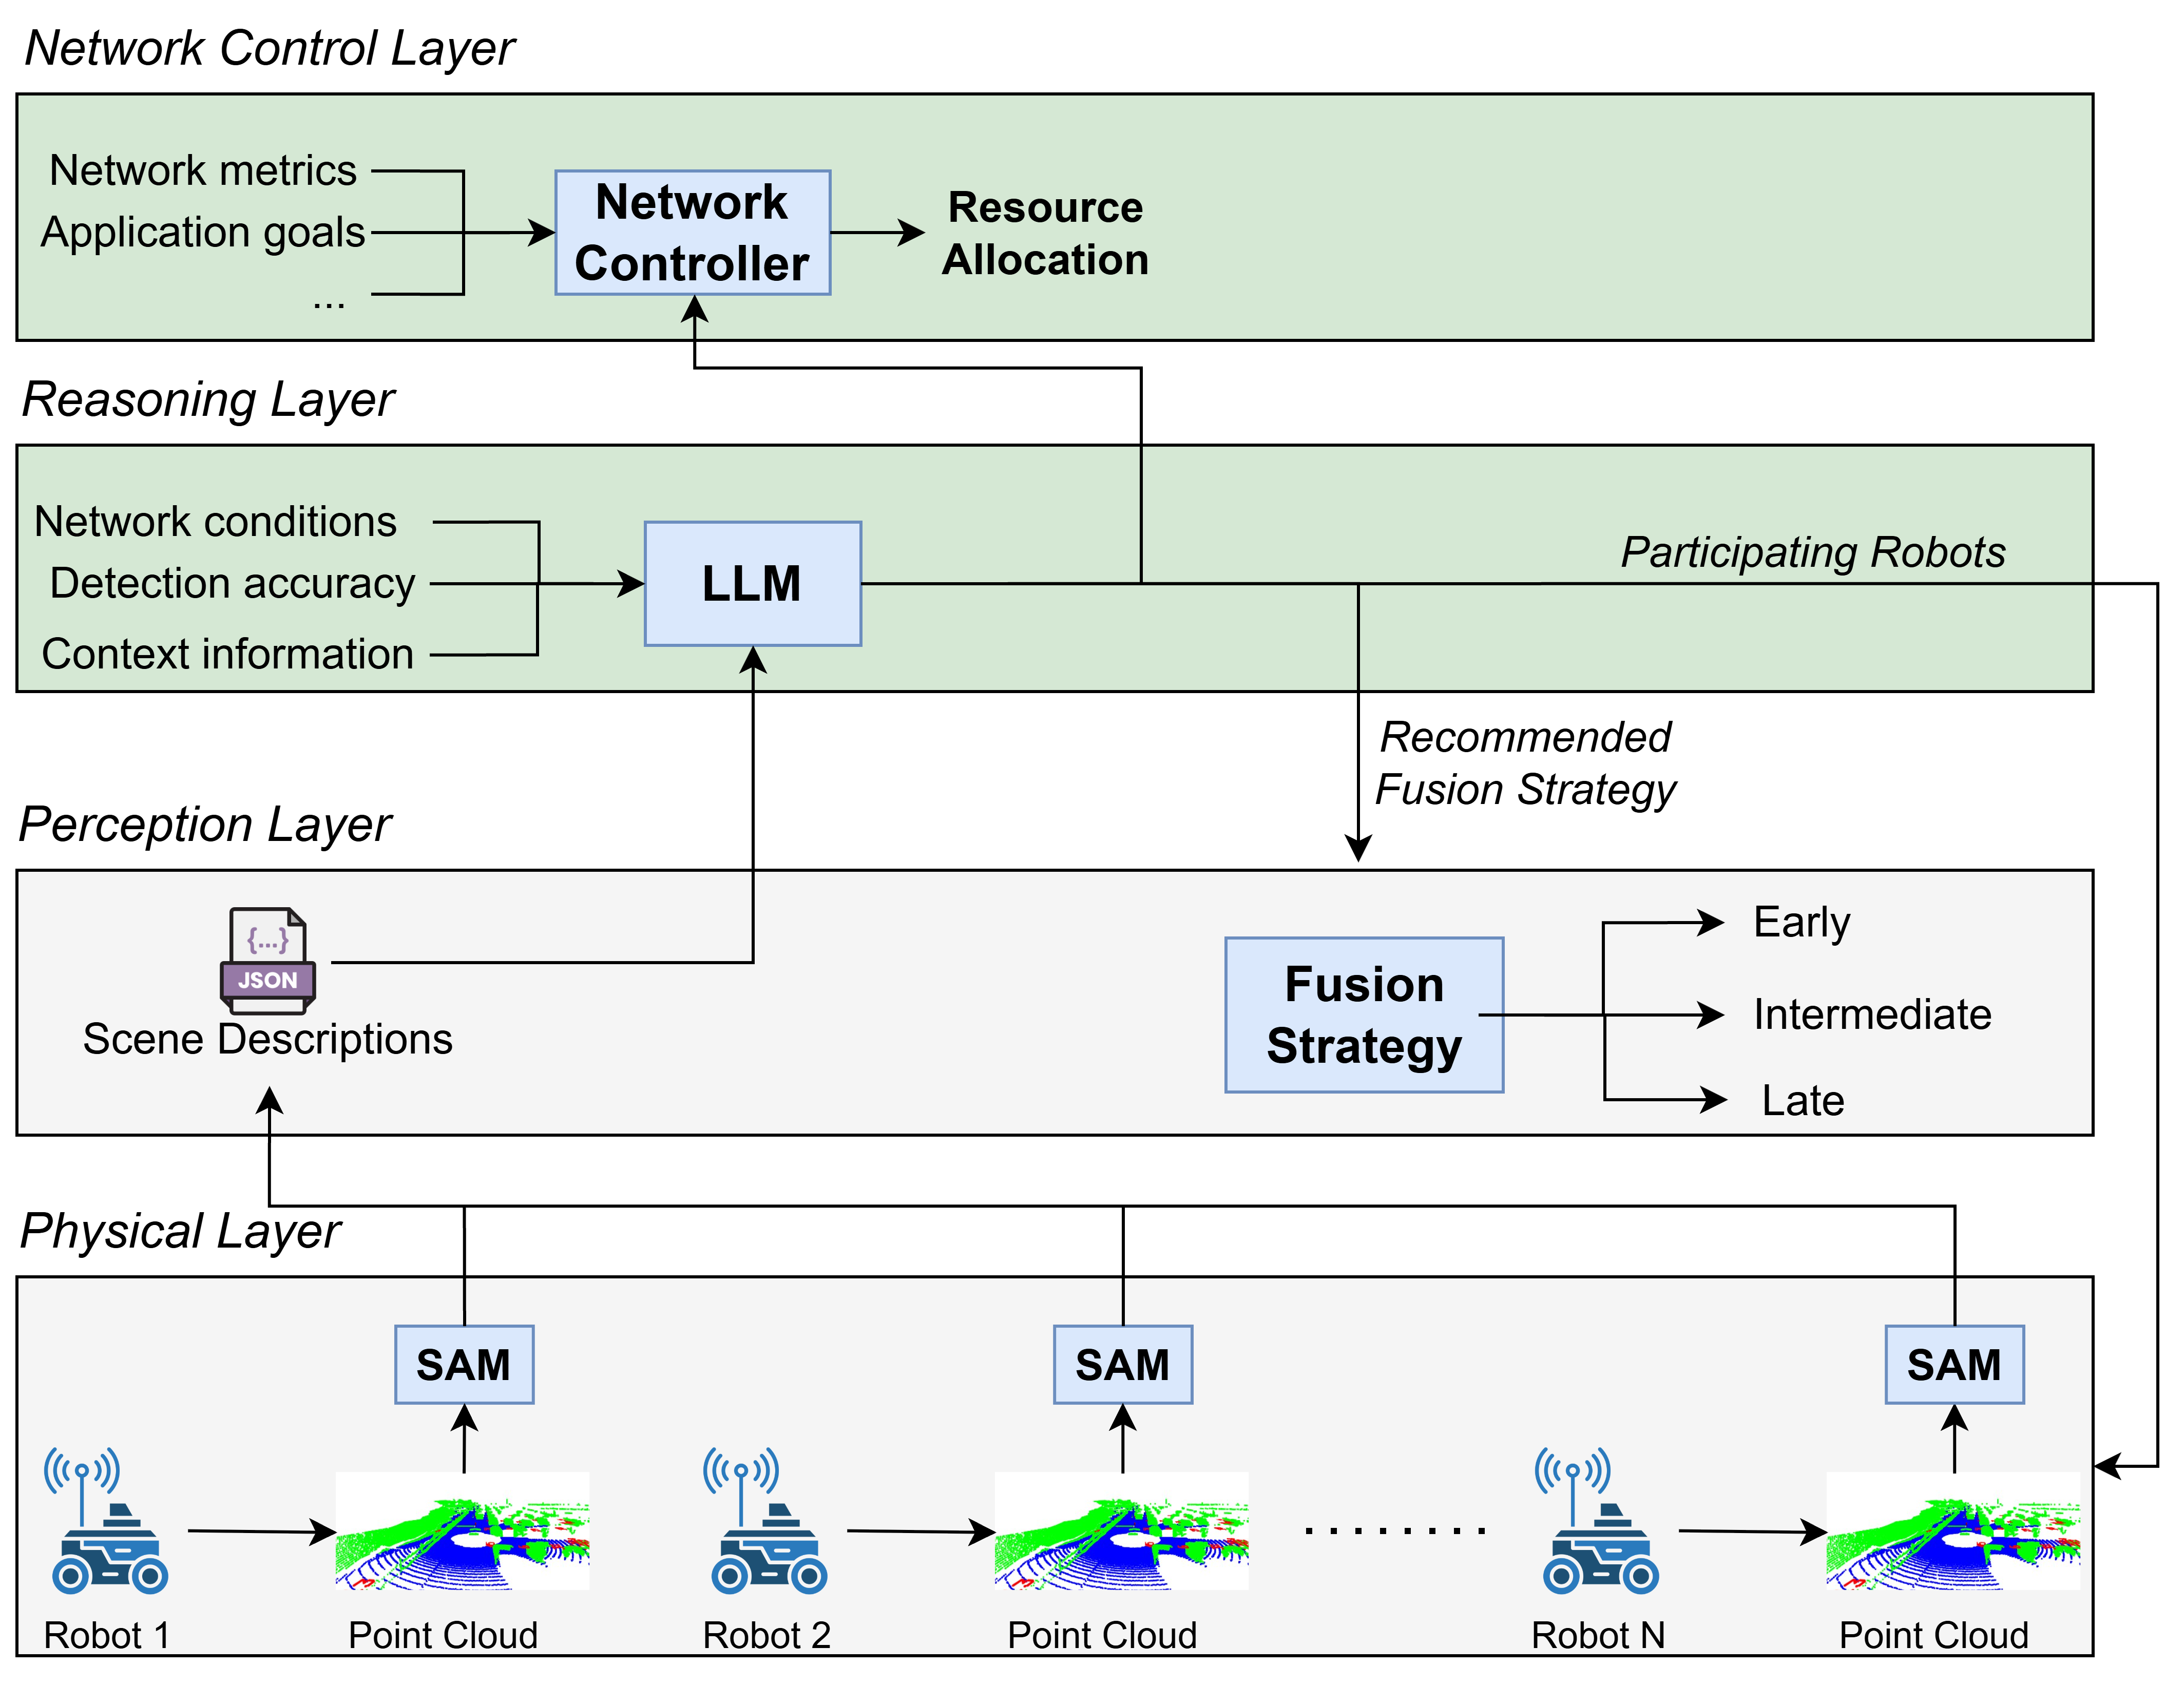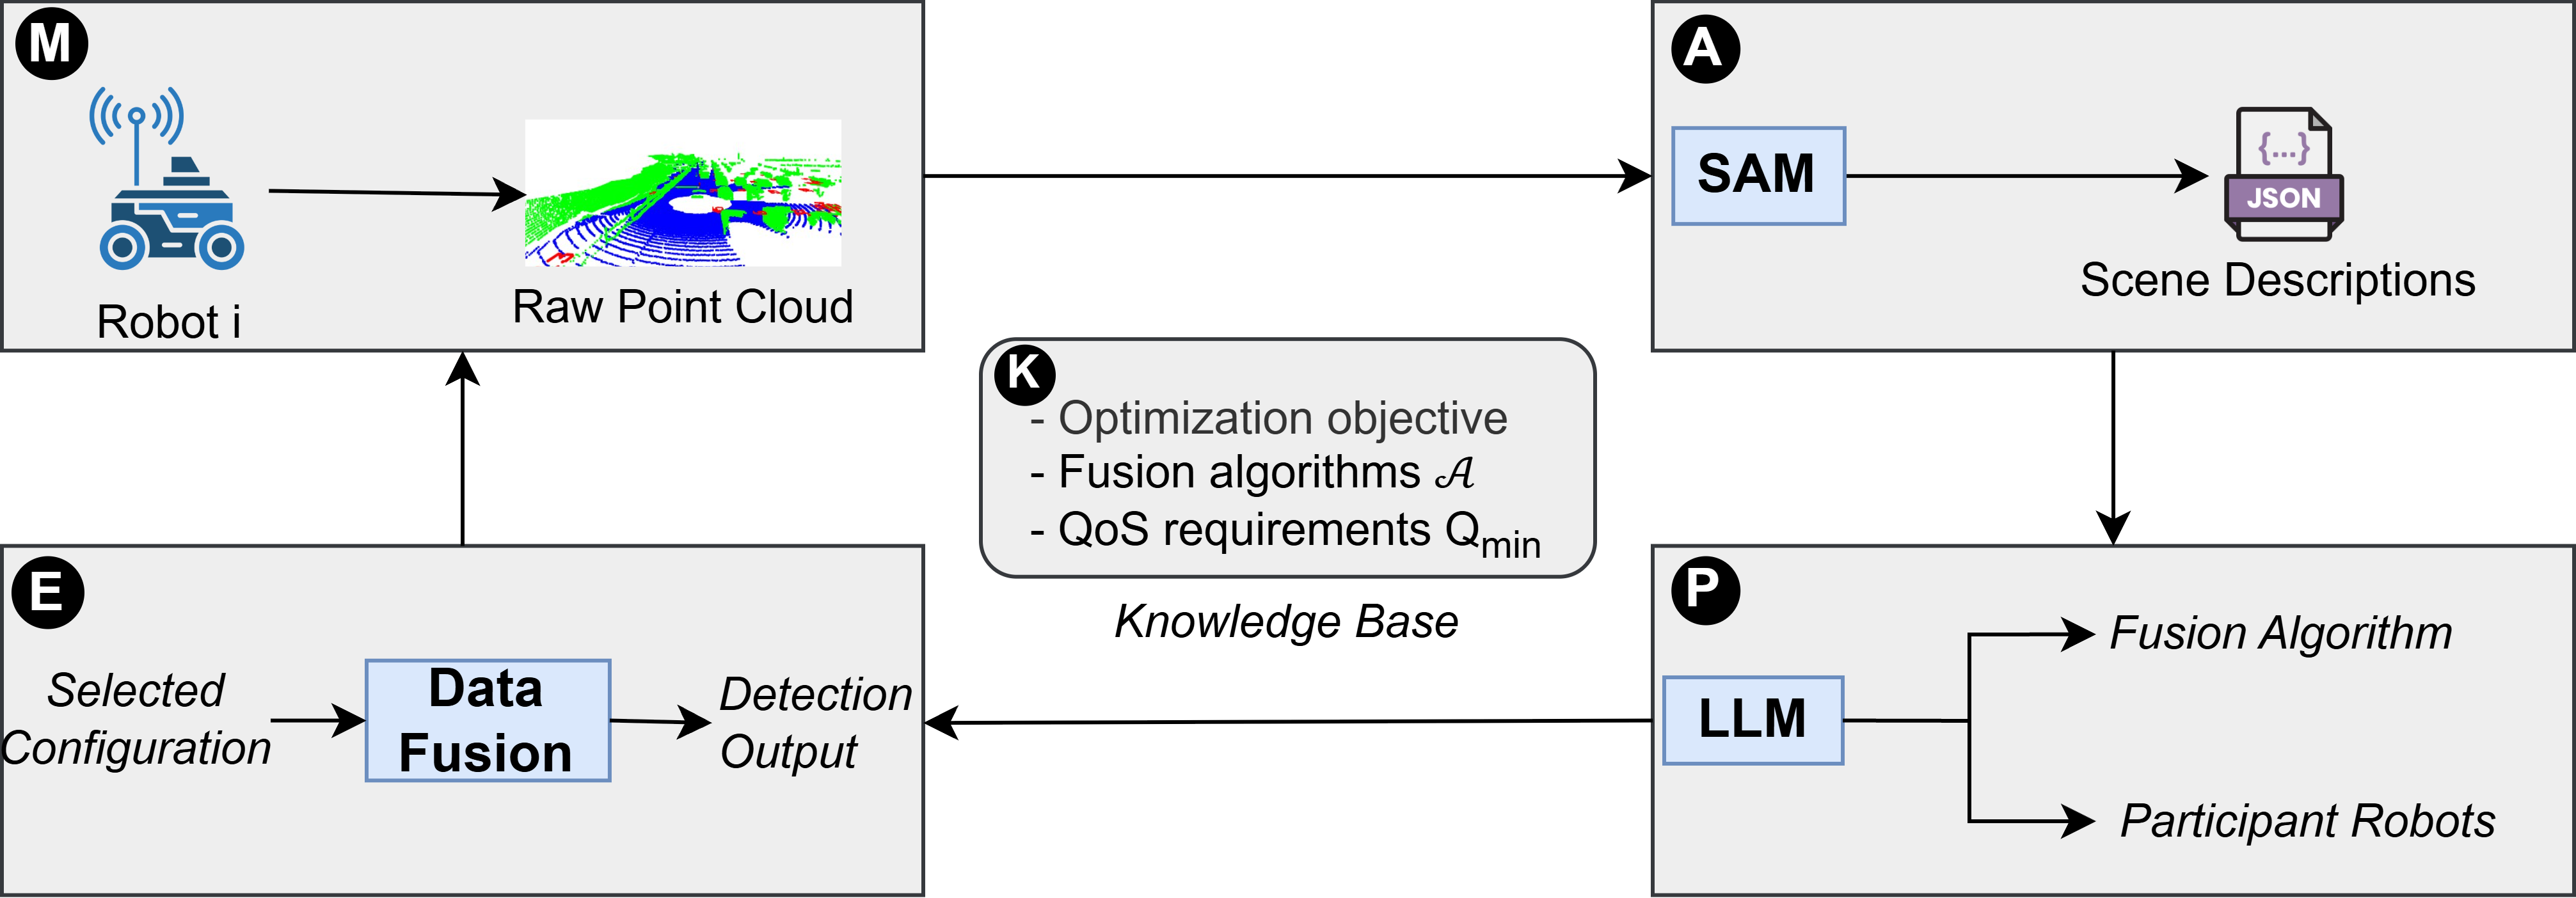
CoAdapt os an adaptive collaborative perception framework that jointly optimizes participant selection and fusion strategy at runtime, balancing detection precision against communication cost in dynamic IIoT swarm deployments. Our approach introduces a Scene Abstraction Module that converts raw LiDAR point cloud data into structured natural language descriptions of the swarm’s spatial configuration, enabling a Large Language Model (LLM) to serve as an autonomic fusion controller. At each control cycle, the LLM receives a description of the current environment state, and produces a joint decision that includes the subset of robots that participate in the fusion process, and the fusion algorithm to apply.
CoAdapt is built on top of the OpenCOOD library for running data fusion on LiDAR data, and uses the OPV2V dataset.
CoAdapt’s high-level architecture is shown below: